Mechanical engineering · Aerospace · Stevens Institute of Technology

Jack Ceriello

I design, build and test things that go fast: electric race boats, UAVs and composite flight hardware. Co-founder and engineering lead of Stevens Electric Boatworks; most recently a mechanical fabrication intern at Johns Hopkins APL.

Experience

Johns Hopkins Applied Physics Lab · Laurel, MD

Mechanical Fabrication Intern

May – Aug 2026

Composite flight hardware for UAVs and NASA space missions.

  • Owned a new lightweight wing design for a jet-powered UAV
  • Hand-laid carbon fiber parts for NASA missions
  • Carbon fiber layup
  • Composites
  • Wing design
  • UAV structures
  • Flight hardware
  • RF materials
  • Prototyping
More details
  • Proposed a new lightweight wing design for a high-volume, jet-powered C5ISRT UAV and was given free rein to design, fabricate and optimize it.
  • Hand-laid carbon fiber layups for large and small flight-model parts bound for NASA space missions.
  • Proposed and prototyped a radome with tunable permittivity, doping composite layups with pyro/ferroelectric powder so the dielectric constant can be actively controlled.

Getinge · Wayne, NJ

R&D Engineering Intern

May – Oct 2025

Automated a manual product test with a 6-axis fixture I built end to end.

  • Saves hundreds of engineering hours a year
  • Design, prototyping, electronics, code and procedure
  • SolidWorks
  • Test automation
  • Fixture design
  • FDM & SLA printing
  • Electronics
  • Programming
  • Design reviews
More details
  • Designed and built a 6-axis automated fixture for a life-cycle test on a flagship product, replacing a manual process that took hundreds of engineering hours a year.
  • Owned it end to end: mechanical design, rapid prototyping (FDM and SLA), electronics, programming and writing the procedure.
  • Designed a tool for a recurring production-floor issue to improve the technicians’ workflow.
  • Led weekly design reviews and presented to technical and non-technical audiences.

Parziale Research Group · Stevens Shock Tunnel Lab

Volunteer Research Assistant

Dec 2024 – May 2025

Helped run the Stevens Shock Tunnel for hypersonic boundary-layer research.

  • Worked alongside PhD researchers
  • Turned the tunnel around between tests
  • Hypersonics
  • Boundary-layer flow
  • Wind tunnel testing
  • Lab procedures
More details
  • Helped PhD students run the Stevens Shock Tunnel to collect data on hypersonic boundary-layer flow.
  • Turned the tunnel around between tests: replacing diaphragms, cleaning and resetting.
  • Learned experimental techniques and lab protocols from experienced researchers.

Daedalus Engineering Designs

Founder & CAD Engineer

Jan 2025 – present

Custom CAD and 3D-printed prototypes for clients.

  • Designs built around each client’s manufacturing needs
  • Run timelines, revisions and client communication
  • SolidWorks
  • Fusion 360
  • 3D printing
  • Design for manufacturing
  • Client management
More details
  • Design custom CAD models for clients around their manufacturing and project requirements.
  • Run client communication, timelines and revisions, and build 3D-printed prototypes to refine designs.

Projects & teams

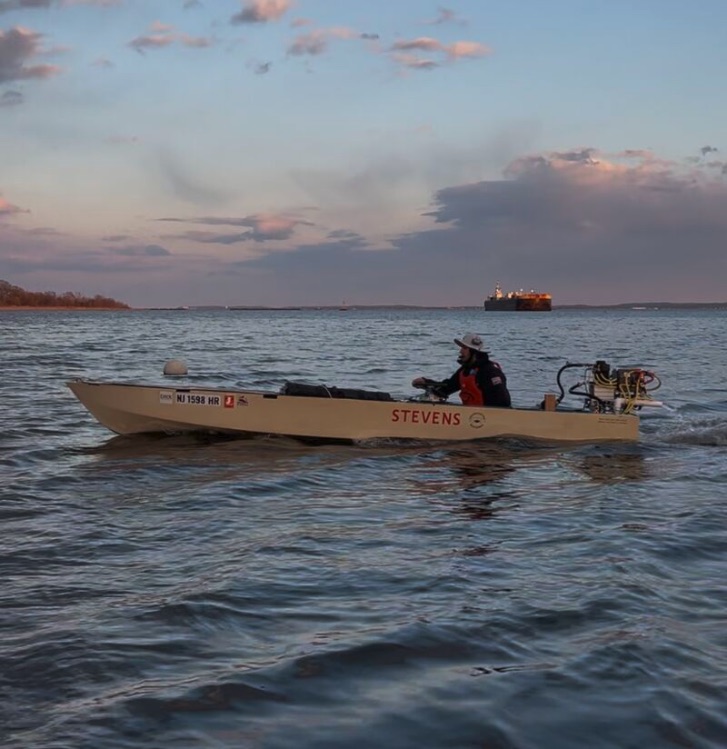
The Stevens electric boat running at sunset
Photos: Stevens Electric Boatworks and Stevens Institute of Technology.

Stevens Electric Boatworks · Co-founder, Engineering Lead, Treasurer

Electric race boats

Dec 2024 – present

Co-founded and help lead a 30+ person team that designs, builds and races electric boats.

  • 1st place, 2025 ASNE + Navy PEP (race and white paper); 3rd in manned planing, 2026
  • 2027 goal: a crewed hydroplane near 100 knots
  • Treasurer: run the team’s budget and spending
  • Team leadership
  • Budgeting
  • Propulsion
  • Battery design
  • Cooling systems
  • CAN bus
  • Telemetry
  • Raspberry Pi
  • Python
  • Milling
  • 3D printing
  • Composites
More details
  • Help lead the team: project direction, engineering decisions and budget. Lead sub-teams and train new members.
  • First place at the 2025 ASNE + Navy PEP competition for race performance and the engineering white paper; consistently on the podium. At the 2026 competition in Portsmouth, VA the team took 3rd in the manned planing division and fielded a newly designed autonomous vessel.
  • Design, mill and 3D print components across the boats’ subsystems, and diagnose mechanical, electrical and motor-controller failures to keep the boat running.
  • Ran cooling-system test campaigns for flow rate, pressure and temperature data.
  • Worked on live telemetry with Raspberry Pi, Arduino and CAN bus (Python, Java, Linux): cooling and propulsion sensor data is logged and streamed to a shore ground station for safer, higher-speed testing.
  • 2025–26 season: redesigned every major system, including closed + open-loop sea-water cooling, a ~1000 A battery and electrical architecture for a new dual-motor setup on VESC controllers, a new motor mount, transmission and upper and lower units for the outboard, and all of the software. Also started an autonomous uncrewed vessel for a fully autonomous 2-mile race, targeting 35–40 knots.
  • 2027 crewed boat: a 3000 A, 15s50p Li-ion pack of 750 Samsung 21700 cells with copper-nickel busbars; sea-water and closed-loop cooling; twin dual-wound axial-flux motors (DHX Peregrine P40) on a custom 180+ hp outboard; an onboard CAN controller; and a retrofitted three-point hydroplane aiming near 100 knots.
  • 2027 uncrewed boat: a new 9 ft carbon fiber tunnel hull targeting about 80 knots.
  • Set up the team’s shared CAD server with check-out locks so 30 people can work on one assembly (see Software).
Personal project

Long-range fixed-wing UAS

Oct 2023 – present

A long-range UAV with a wireless datalink and autonomous missions.

  • Optimized with CFD and XFOIL
  • Now moving to a multi-engine layout
  • Aircraft design
  • SolidWorks
  • SolidWorks CFD
  • Ansys Fluent
  • XFOIL
  • ArduPilot
  • Avionics integration
  • Additive manufacturing
More details
  • Built to learn aircraft design, flight testing and long-range datalinks hands-on.
  • Used SolidWorks CFD and XFOIL to test and optimize efficiency and performance.
  • Several iterations and full redesigns to improve stability, control, electronics integration and ease of manufacturing.
  • The multi-engine layout removes the left-turning tendency, allows smaller propellers and higher thrust-to-weight, and makes room for a SIYI A2 gimbaled FPV camera and better mounting for the SIYI HM30 air unit.

Personal project

Full-motion flight simulator

Oct 2024 – present

A simulator that spins the pilot a full 360° in pitch and roll, with an F/A-18 cockpit and VR.

  • Welded frame, machined parts, FEA-checked
  • Pitch axis running and in testing
  • SolidWorks
  • FEA
  • Hand calculations
  • Welding
  • Machining
  • Motor control
  • Controls
  • Systems integration
More details
  • Rotates at high rates in both axes, with a replica F/A-18 Hornet cockpit and a VR headset.
  • Took it from concept to a working machine: design, safety checks by hand calculation plus static and motion simulation, machined parts and a fully welded frame.
  • Designed and implemented the electrical system (motors, motor controllers, sensors) with an electrical engineering student.
  • The pitch axis is running and being tested to validate the design and develop the controls.

Senior capstone · Planetary Gearbox Lead

H.Y.D.R.A. two-speed actuator

Sep 2026 – present

High Yield Dual Ratio Actuator: one gearbox that shifts between high torque and high speed.

  • Planetary and cycloidal stages in series
  • I lead the planetary gearbox design and analysis
  • Gear design
  • Planetary gearboxes
  • Cycloidal drives
  • Mechanisms
  • 3D CAD
  • FEA
  • Prototype testing
  • Team of 6
More details
  • High-torque mode runs power through a planetary gearbox and a cycloidal reduction stage in series.
  • A mechanical selector bypasses the cycloidal stage for high-speed mode, sending power straight from the planetary stage to the output through a direct-drive gear path.
  • As Planetary Gearbox Lead, I own the overall design and analysis of the planetary gears.
  • Six-person team with leads for systems, electrical, cycloidal, planetary, structures and testing. The motor drive runs on a custom STM32 board designed in KiCad.
  • Next: concept selection, then gear ratios, torque and speed requirements, the switching mechanism, materials and structural FEA, ending in a working prototype that gets electromechanical testing.

Stevens Institute of Technology

Autonomous pathfinding robot

Mar – May 2024

An Arduino robot that drives itself to LiDAR-given coordinates and dodges obstacles.

  • Finished every task under the time limit
  • Earned every bonus point
  • Arduino
  • Linear algebra
  • Path planning
  • Ultrasonic sensors
  • LiDAR
  • Fabrication
More details
  • Drives to a sequence of random coordinates fed by LiDAR, avoiding obstacles with ultrasonic sensors.
  • Vector math from its current and previous positions sets its heading to each target; it confirms arrival within tolerance before moving on.
  • One of the few robots in the competition to finish every task under the time limit, earning every bonus point.

Personal project

Radio-controlled hydroplane

May 2022 – Aug 2023

An RC hydroplaning hull, built twice.

  • Foam-board proof of concept, then printed PETG
  • Screwless, watertight quick-release lid
  • Fusion 360
  • 3D printing
  • Hydrodynamics
  • Sealing design
  • Iterative testing
More details
  • Version 1: foam board and sealant as a proof of concept. It worked, but the prop-shaft hole leaked and damaged the structure.
  • Version 2: designed in Fusion 360 and printed in PETG; fixed the stern sitting too low, and built a watertight, quick-release lid with no screws after testing several lid and seal designs.
  • Lesson: prop cavitation and ventilation cost speed and control. The transom and prop needed to sit lower, with a different shaft angle.

Software, built with AI

I’m a mechanical engineer, but I like using software to elevate my projects and make parts of my work and life more efficient. Today’s AI tools make building powerful software of any kind unbelievably accessible.

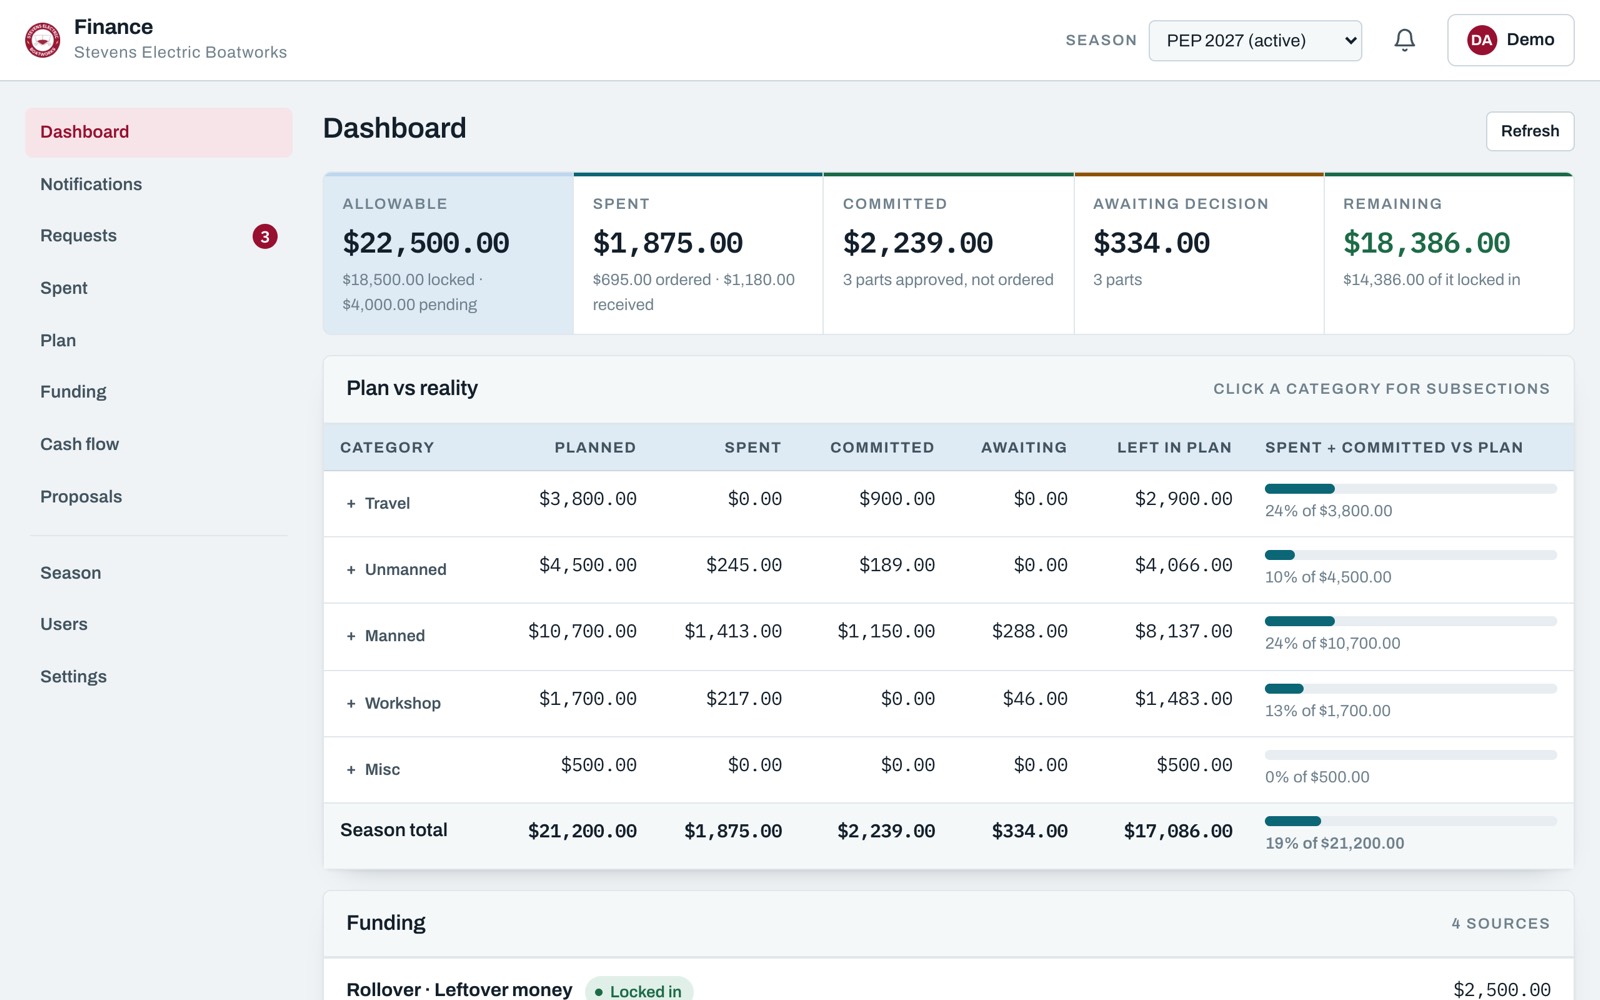
Finance dashboard: budget, spending and plan versus reality by category
Shown with sample data.

Stevens Electric Boatworks

Team finance & purchasing system

One web app running five team sites for a 30+ person team’s spending.

  • Replaced spreadsheets and email threads
  • Requests, budget, orders, tracking and an email archive
  • Claude Code
  • Node.js
  • Express
  • SQLite
  • Email automation
  • Self-hosting
  • Budget tracking
More details
  • Purchase request form for any member; a finance dashboard with the request queue, spending ledger, season budget plan and funding.
  • An orders board for adding tracking numbers and receipts, and a page where anyone can see where their part is.
  • An email archive of vendor and school conversations, saved by CCing one address.
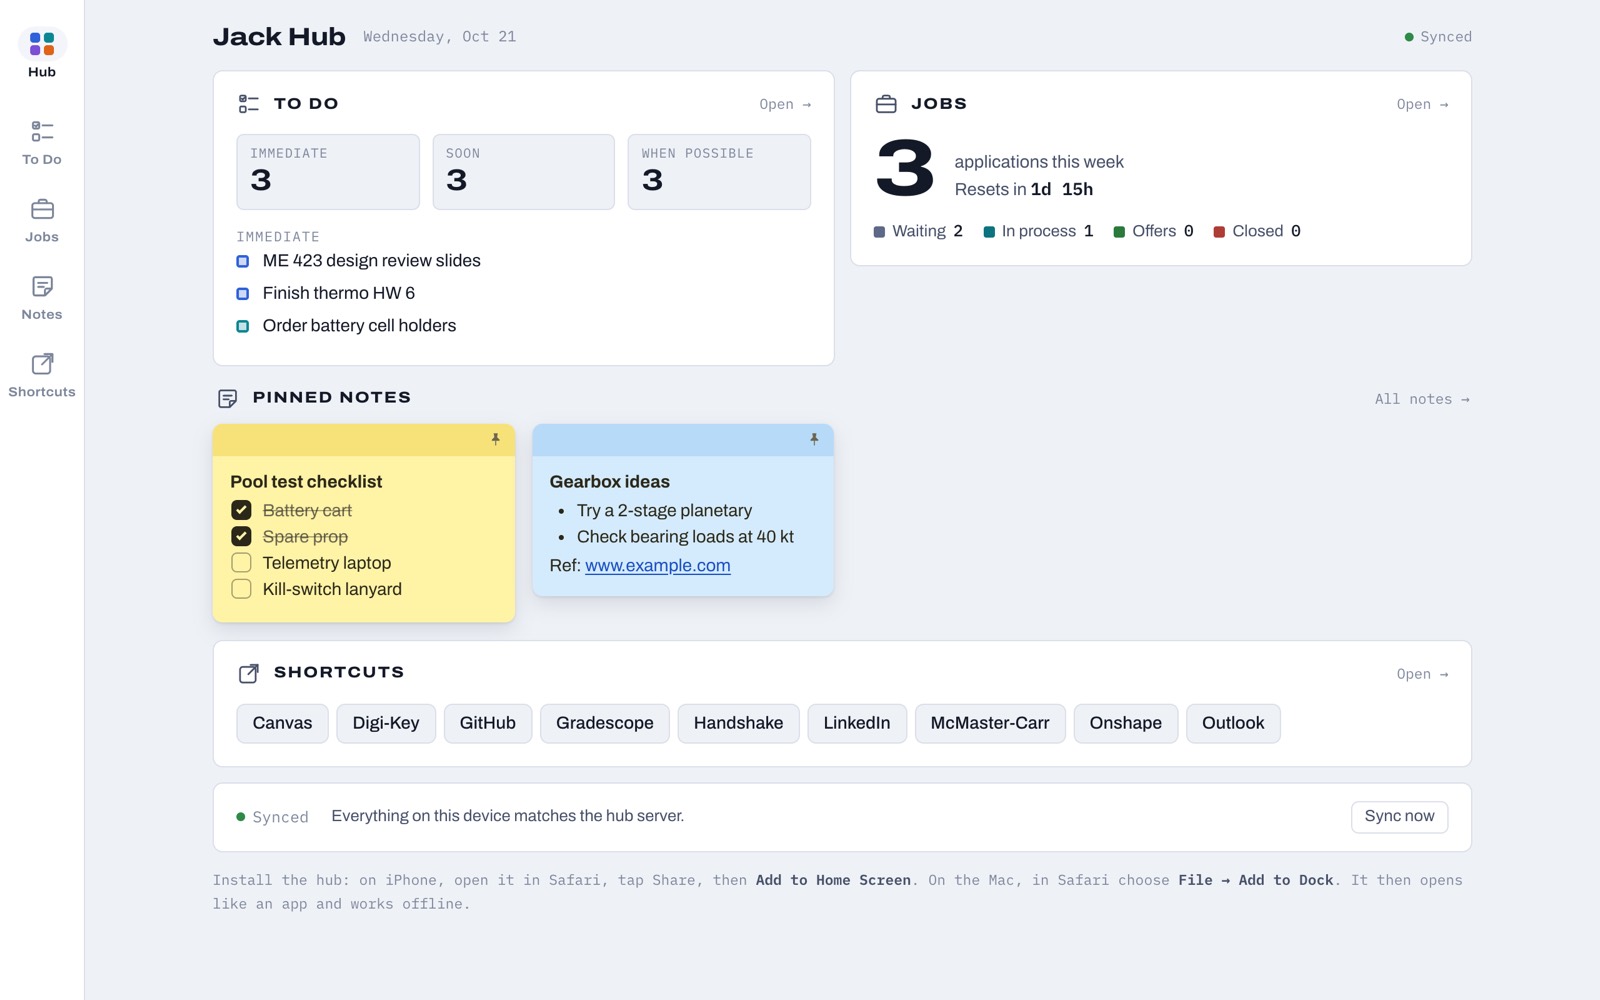
Hub home: to-do summary, job count, pinned notes and shortcuts
Shown with sample data.

Personal

Personal application hub

My to-do list, internship tracker, sticky notes and shortcuts in one app on my phone and laptop.

  • Works offline, syncs when back online
  • Password plus Face ID or 2FA sign-in
  • Claude Code
  • Web app (PWA)
  • Offline-first
  • CouchDB sync
  • Passkeys
  • 2FA
  • Docker
  • Cloudflare Tunnel
More details
  • An installable web app that keeps working with no connection and syncs every device when it reconnects.
  • Self-hosted on my laptop and reached from anywhere through a Cloudflare Tunnel.
  • Its own sign-in: password, then a 2FA code or Face ID passkey, with 60-day trusted devices.
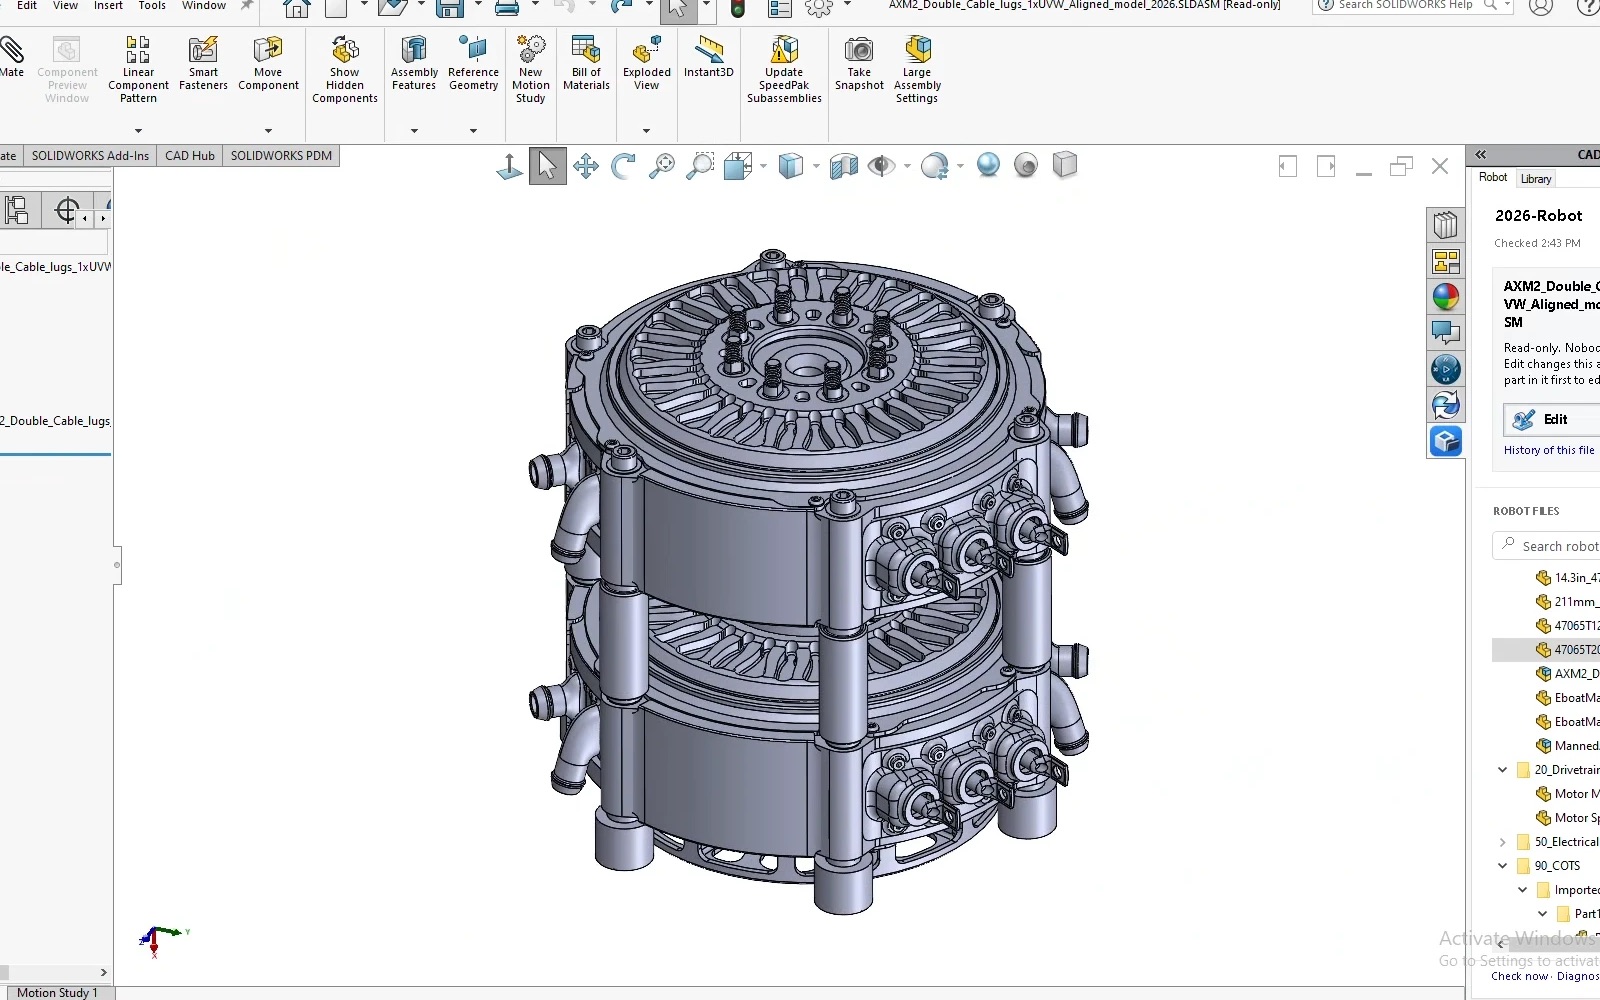
CAD Hub panel inside SolidWorks with the motor assembly open

Stevens Electric Boatworks

Self-hosted team PDM server

Shared SolidWorks storage so 30 people can work on one boat assembly.

  • Check-out locks stop overwritten work
  • Nightly backups and remote access
  • Claude Code
  • SolidWorks
  • SVN
  • Docker
  • Linux
  • Backups
  • Remote access
More details
  • Self-hosted CAD Hub (an open-source SolidWorks add-in and SVN server) with check-out locks and season folders by subsystem: hull, propulsion, gearbox, steering, electrical, controls.
  • Rebranded for the team, with nightly backups and secure remote access for teammates.

One-day builds

Small things built start to finish in a day or a weekend, just to make them.

One-day build

Dodgeball cannon

A combustion-powered cannon that launches a dodgeball.

Skills & certifications

Software
SolidWorks (CAD, CFD, FEA, PDM) · Ansys Fluent & Mechanical · Fusion 360 (CAD/CAM)
Programming
ArduPilot · MATLAB · C++ · Python · Arduino · XFOIL · Linux · Claude Code (AI-built web apps)
Shop
Composites · machining · welding · polymer and metal additive manufacturing
Certified
Private pilot · NASA Bonding & Molding (8739.1) · PADI Open Water · AWS Safety in Welding
Honors
Edwin A. Stevens Scholarship · Presidential Scholarship · Dean’s List every semester
Activities
Stevens Sailing (Treasurer) · AIAA · SNAME · ASNE · SAE Baja · FIRST FTC (2019–2023)

On LinkedIn

Recent posts from me and the team. See everything on LinkedIn